
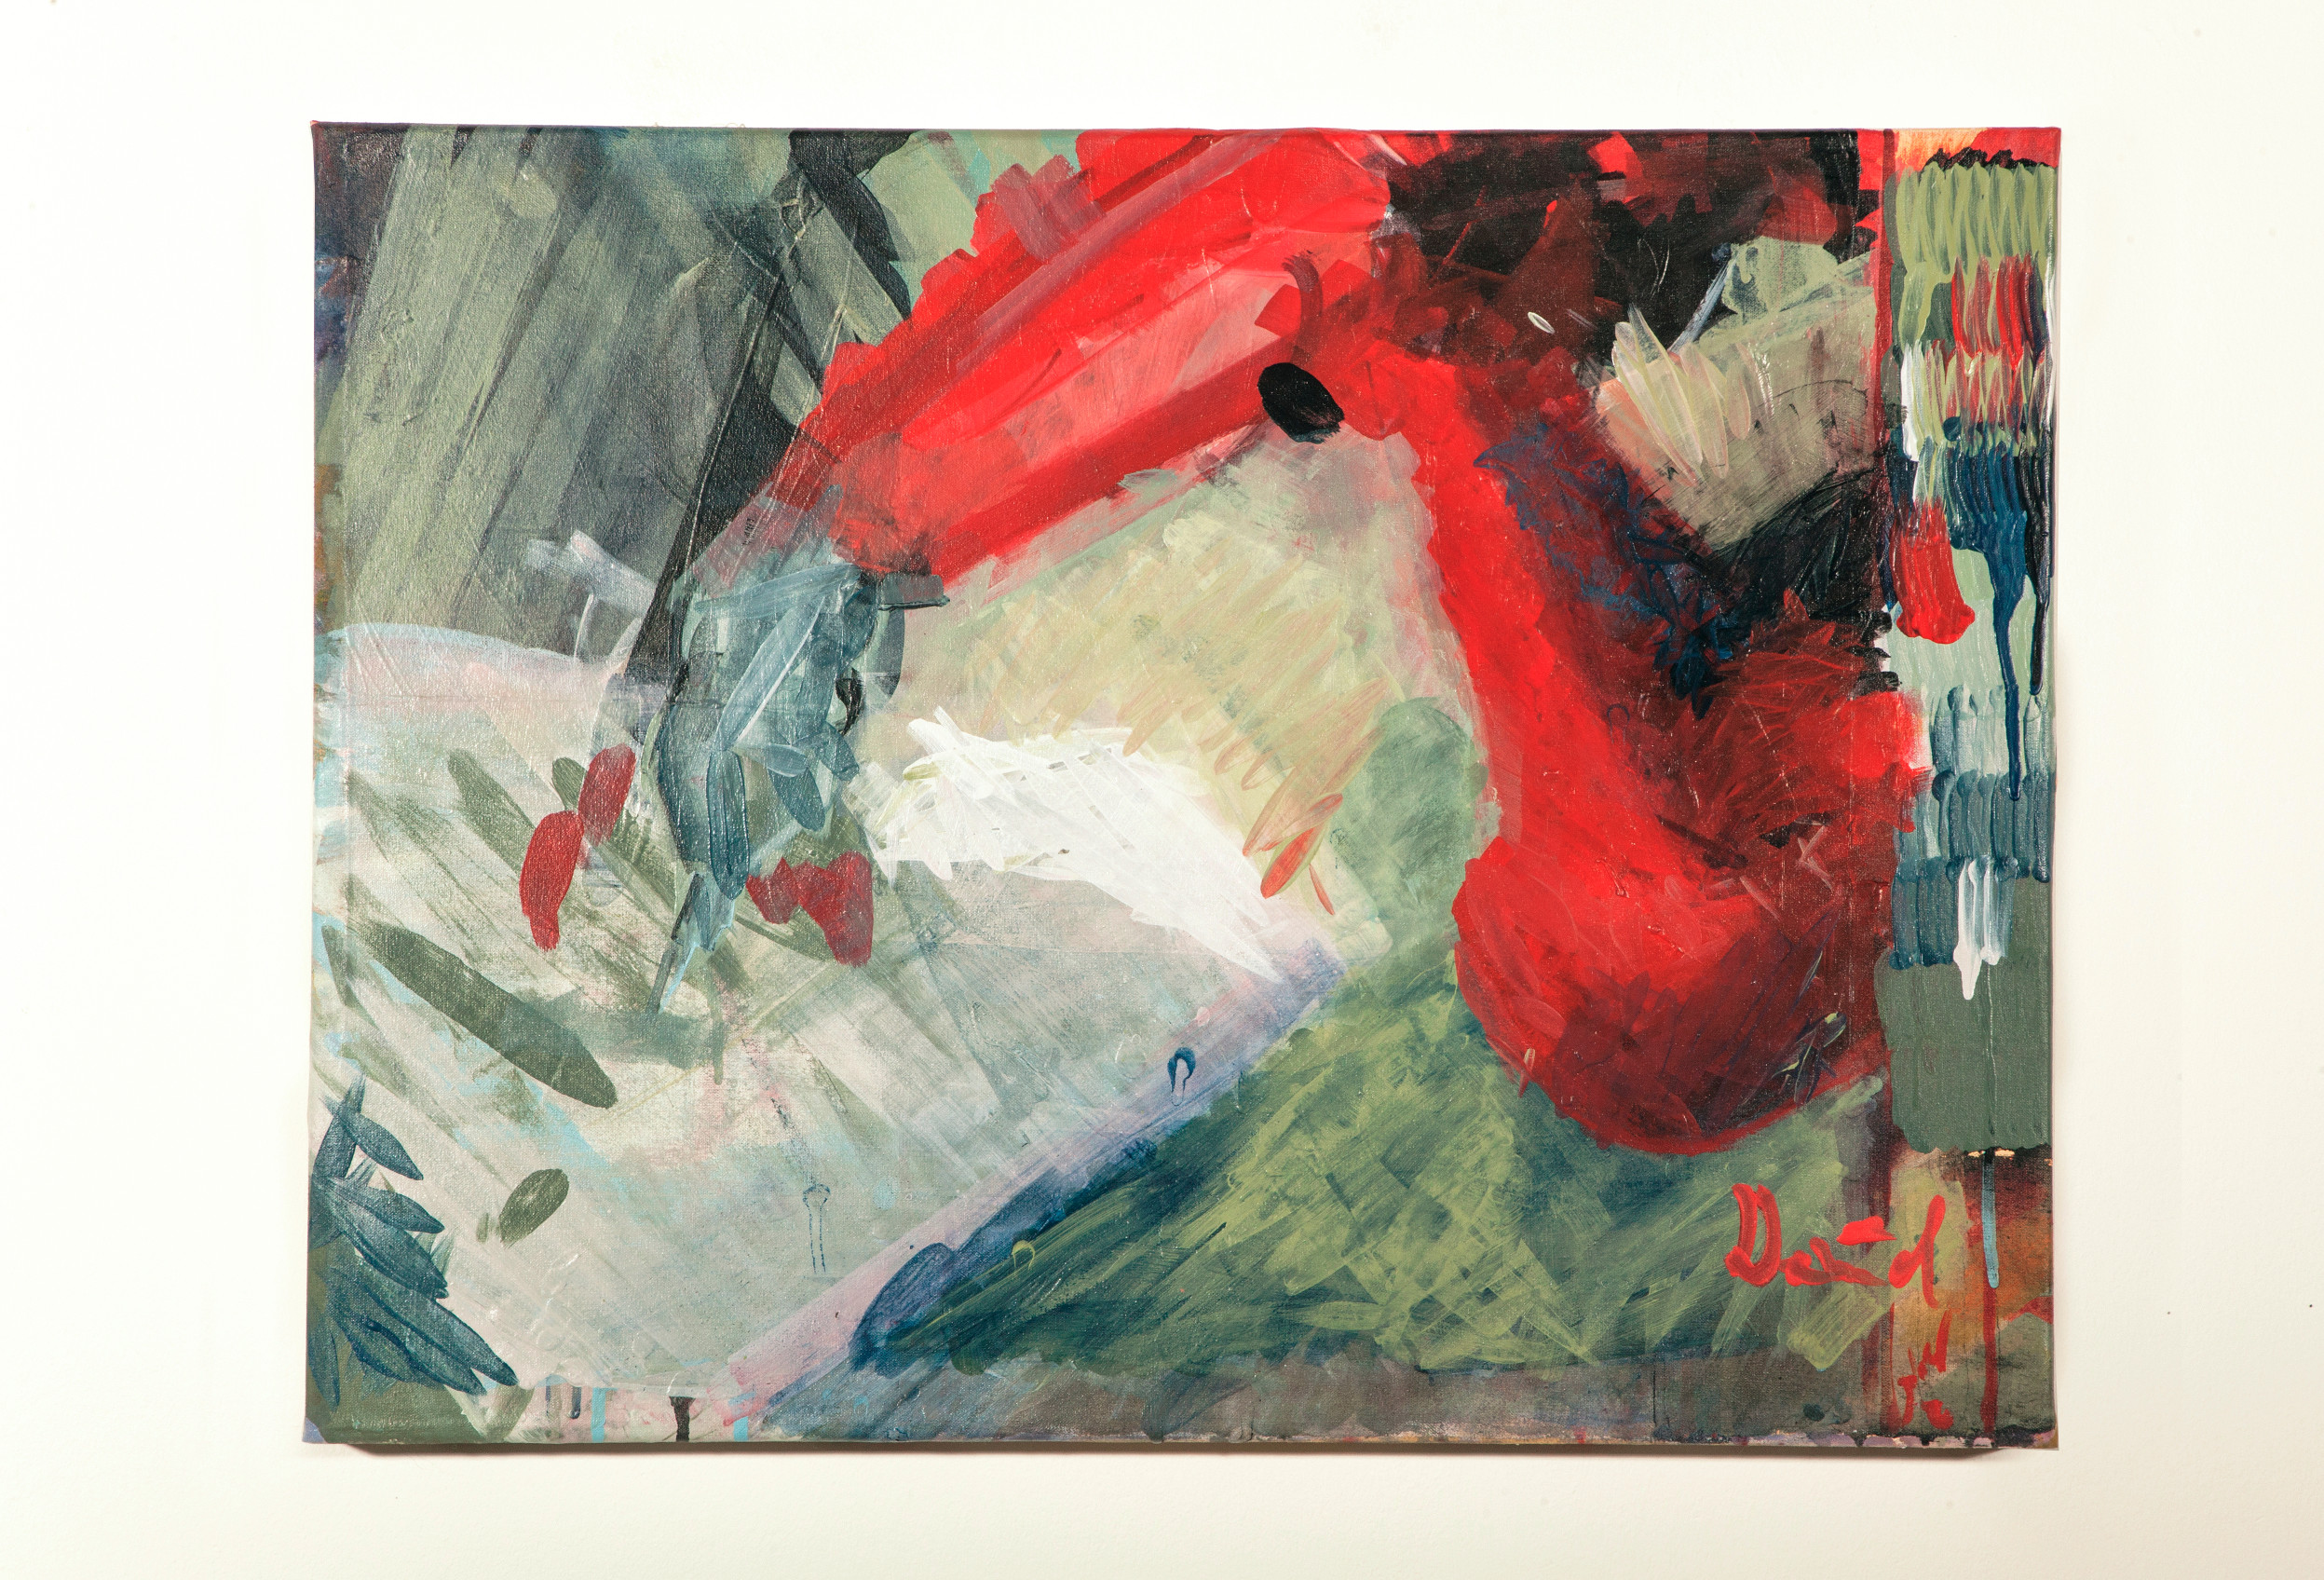
Final painting
Final version of the “Self Portrait” created by the e-David in collaboration with Thomas Lindemeier (programmer) and Liat Grayver (painter). Acrylic on canvas, 60x80, 2016
Inspirational Photo
This is the photo that inspired us to have the e-David create a self portrait. We did not use this or any other photo as input for the actual painting process.
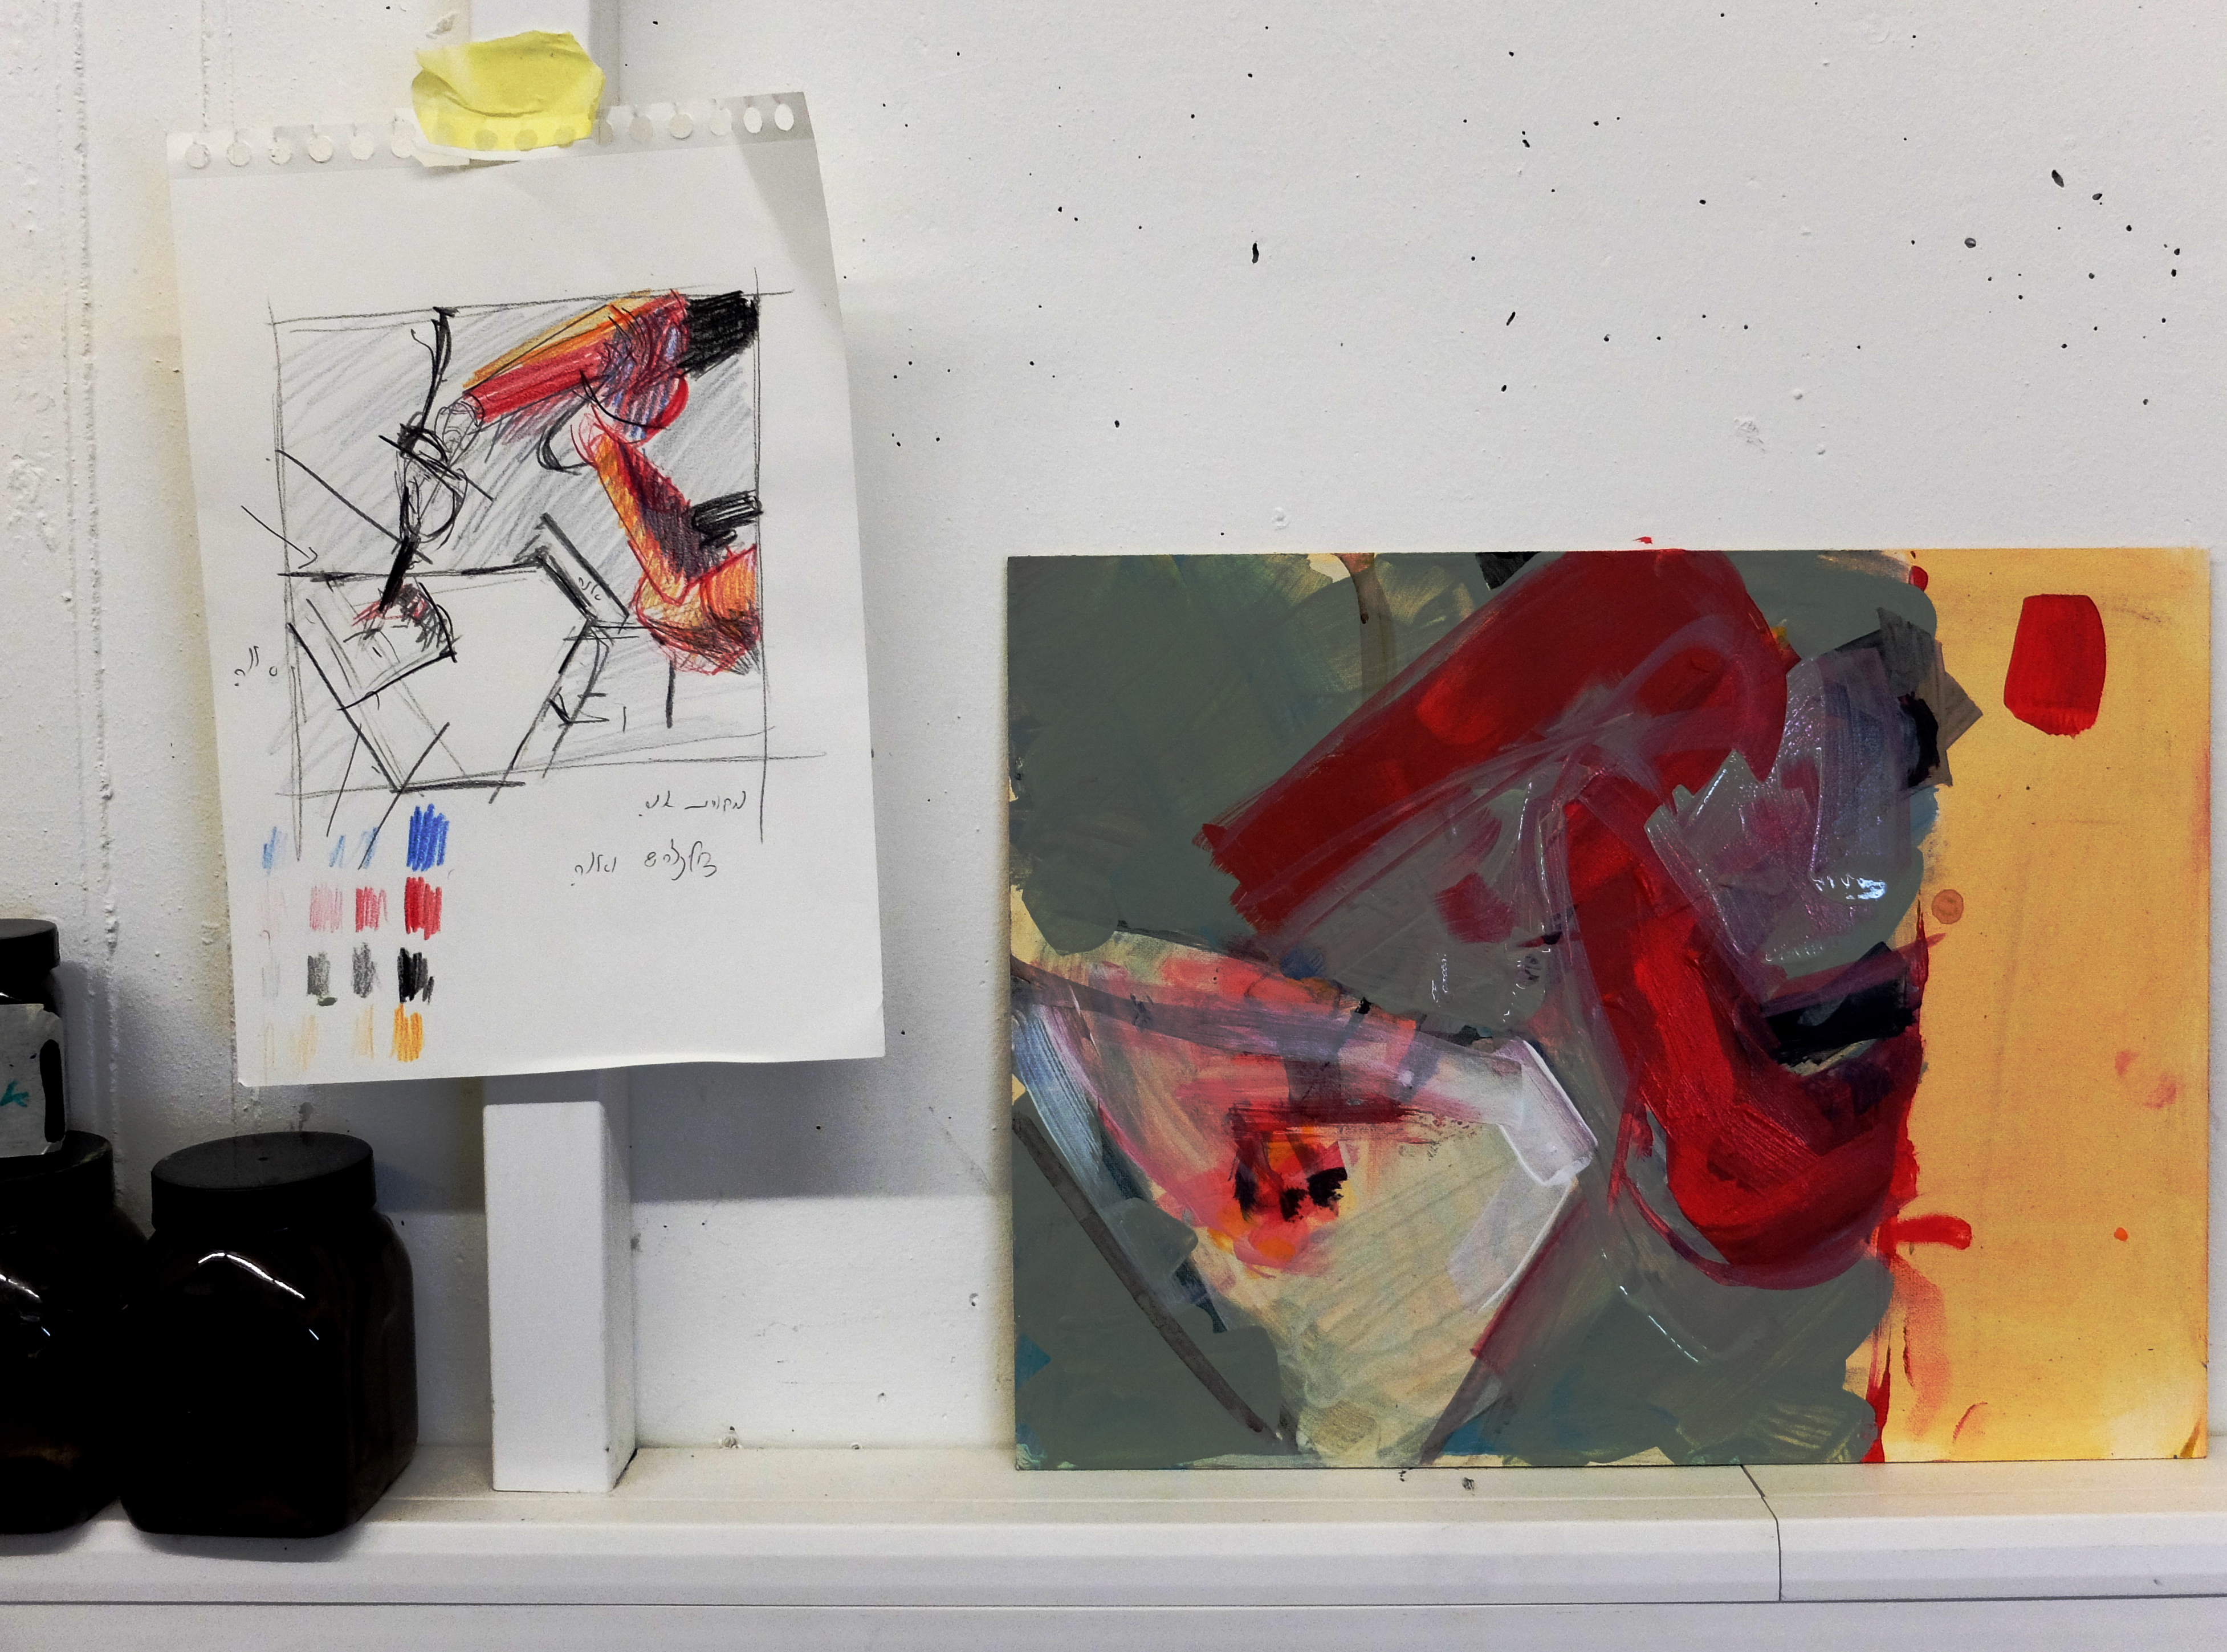
Sketches
Preliminary sketches — sketchpad drawings (coloured pencils) and an oil paint draft made by painter Liat Grayver — that were part of the development stages while planning and preparing to generate e-David’s “Self Portrait”.
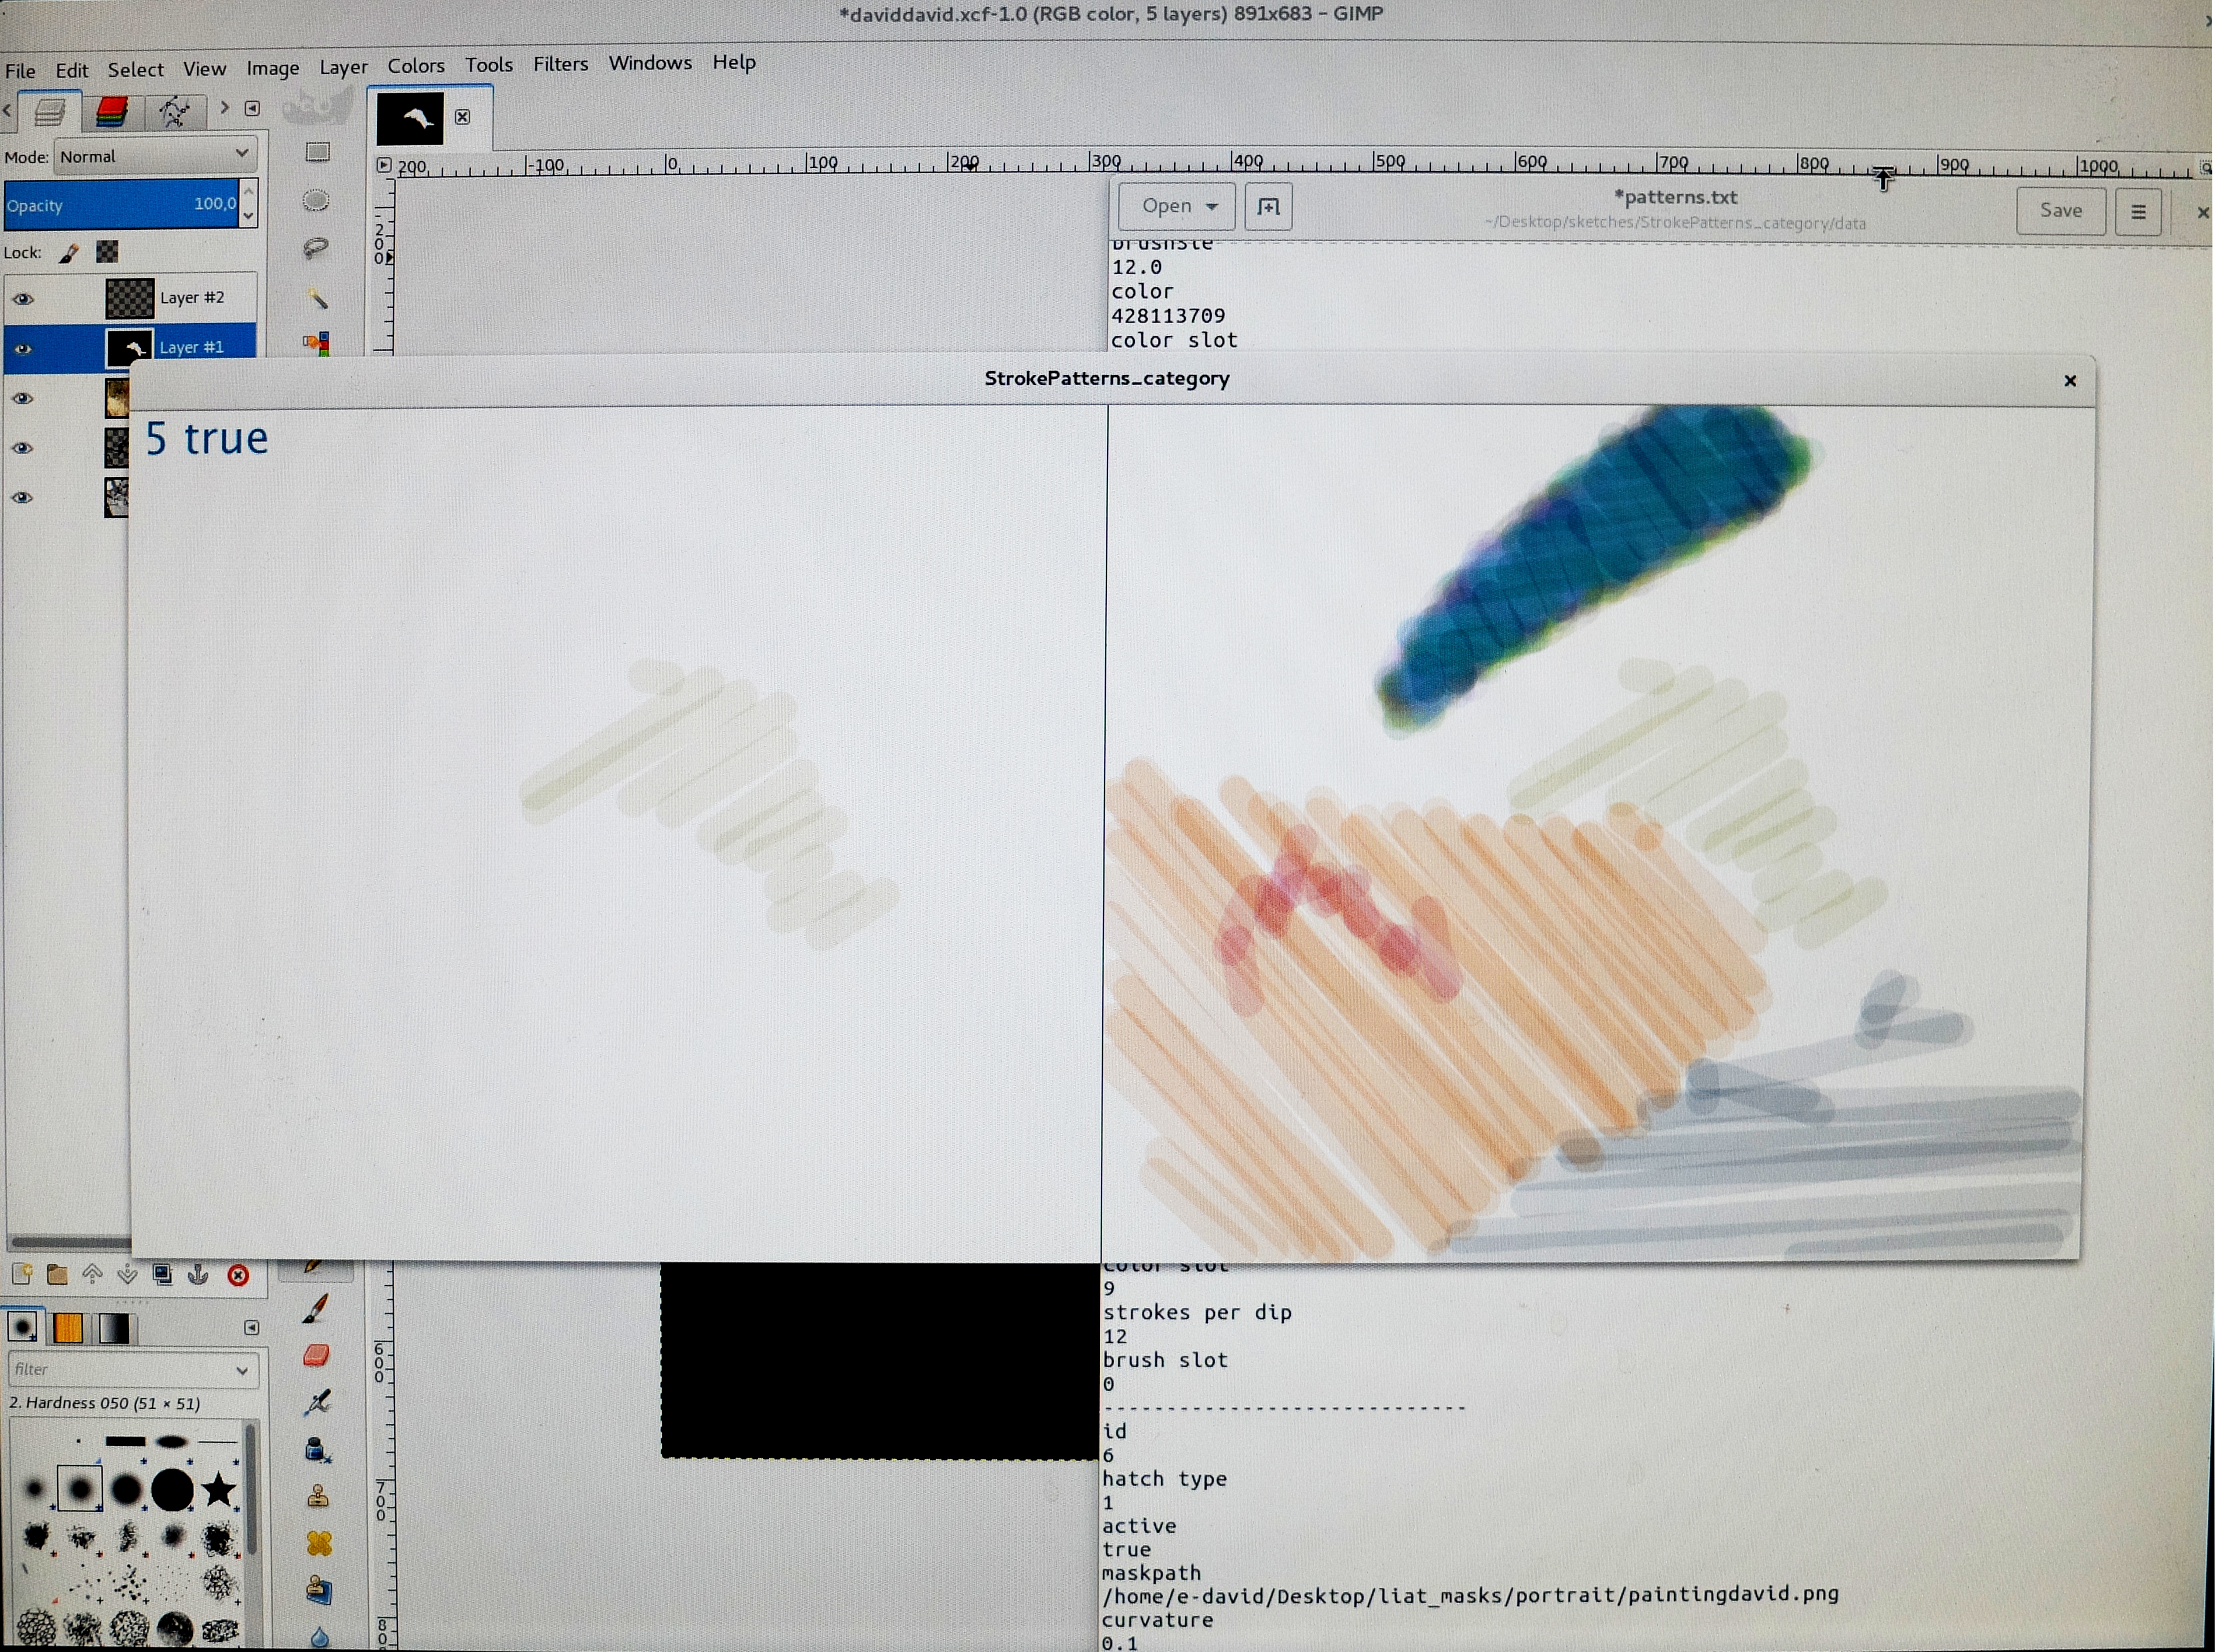
High Level Interface
Snapshot of the high level interface that we implemented specifically for the e-David’s “Self Portrait”.
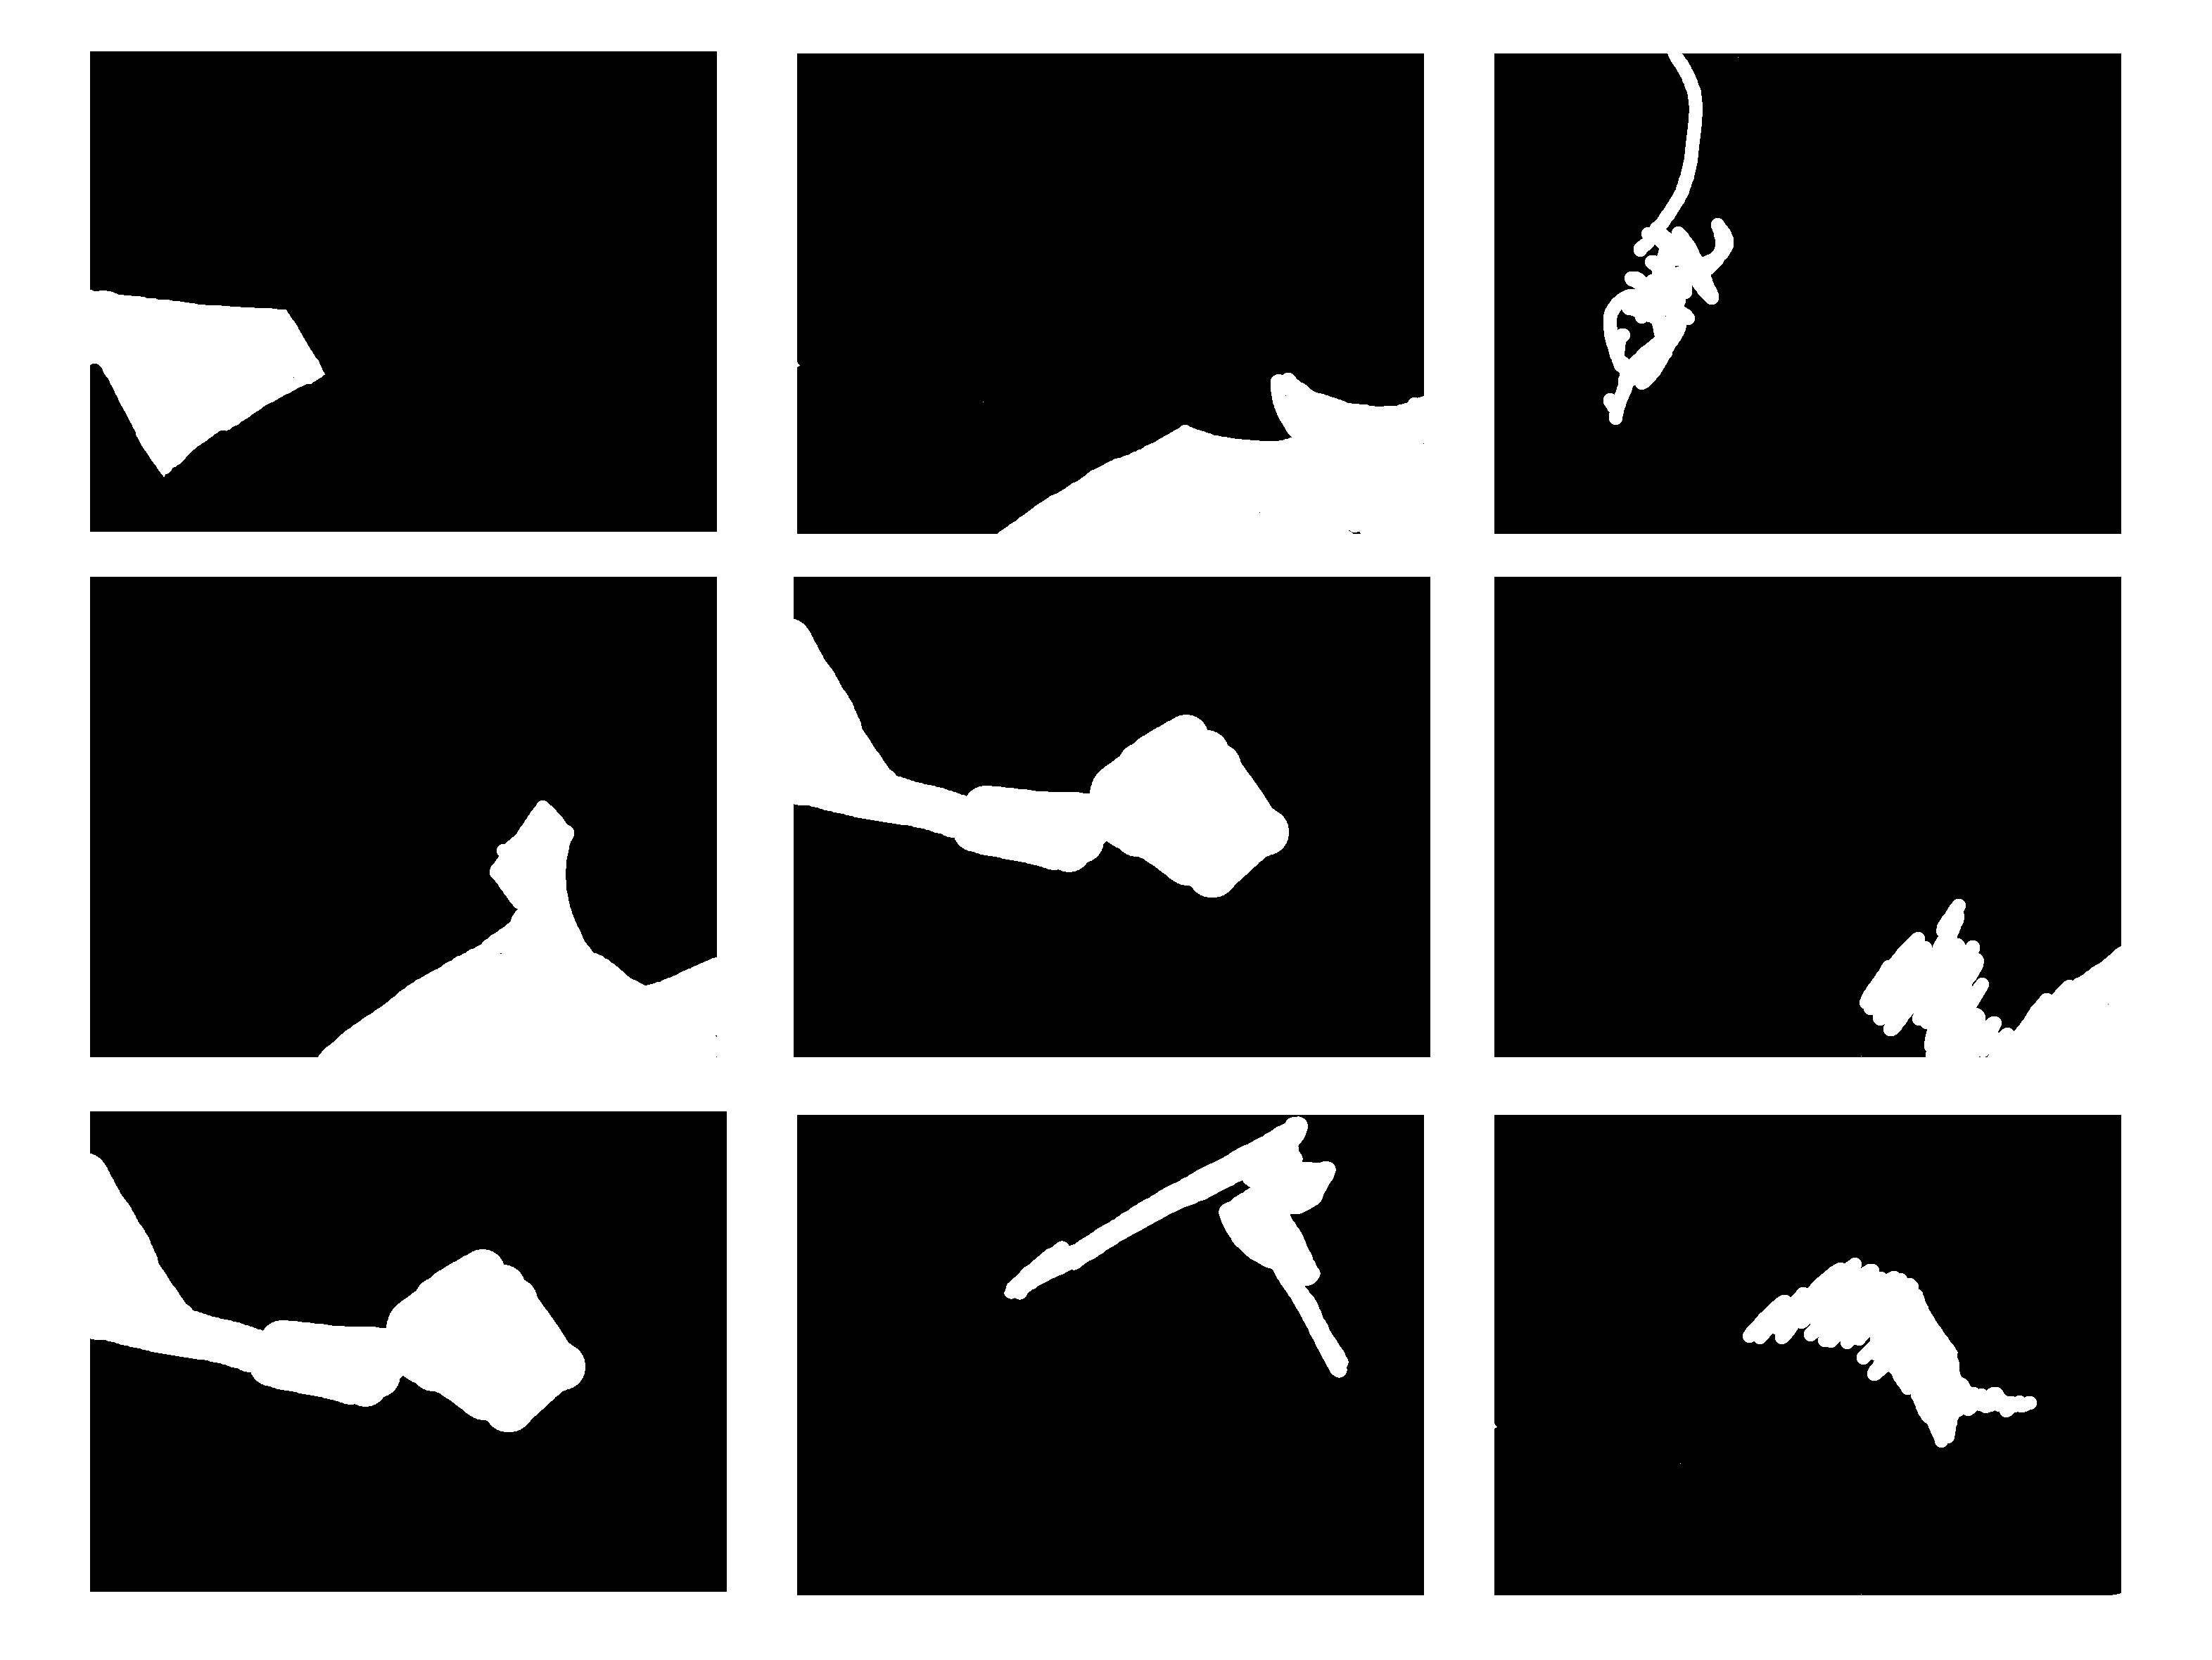
Region Masks
Regions defined by painter Liat Grayver were used to “mask” areas of the virtual canvas (interface) as e-David painted his “Self Portrait”. Different parameters can be set for each individual digital mask, affecting local and global characteristics in the process.
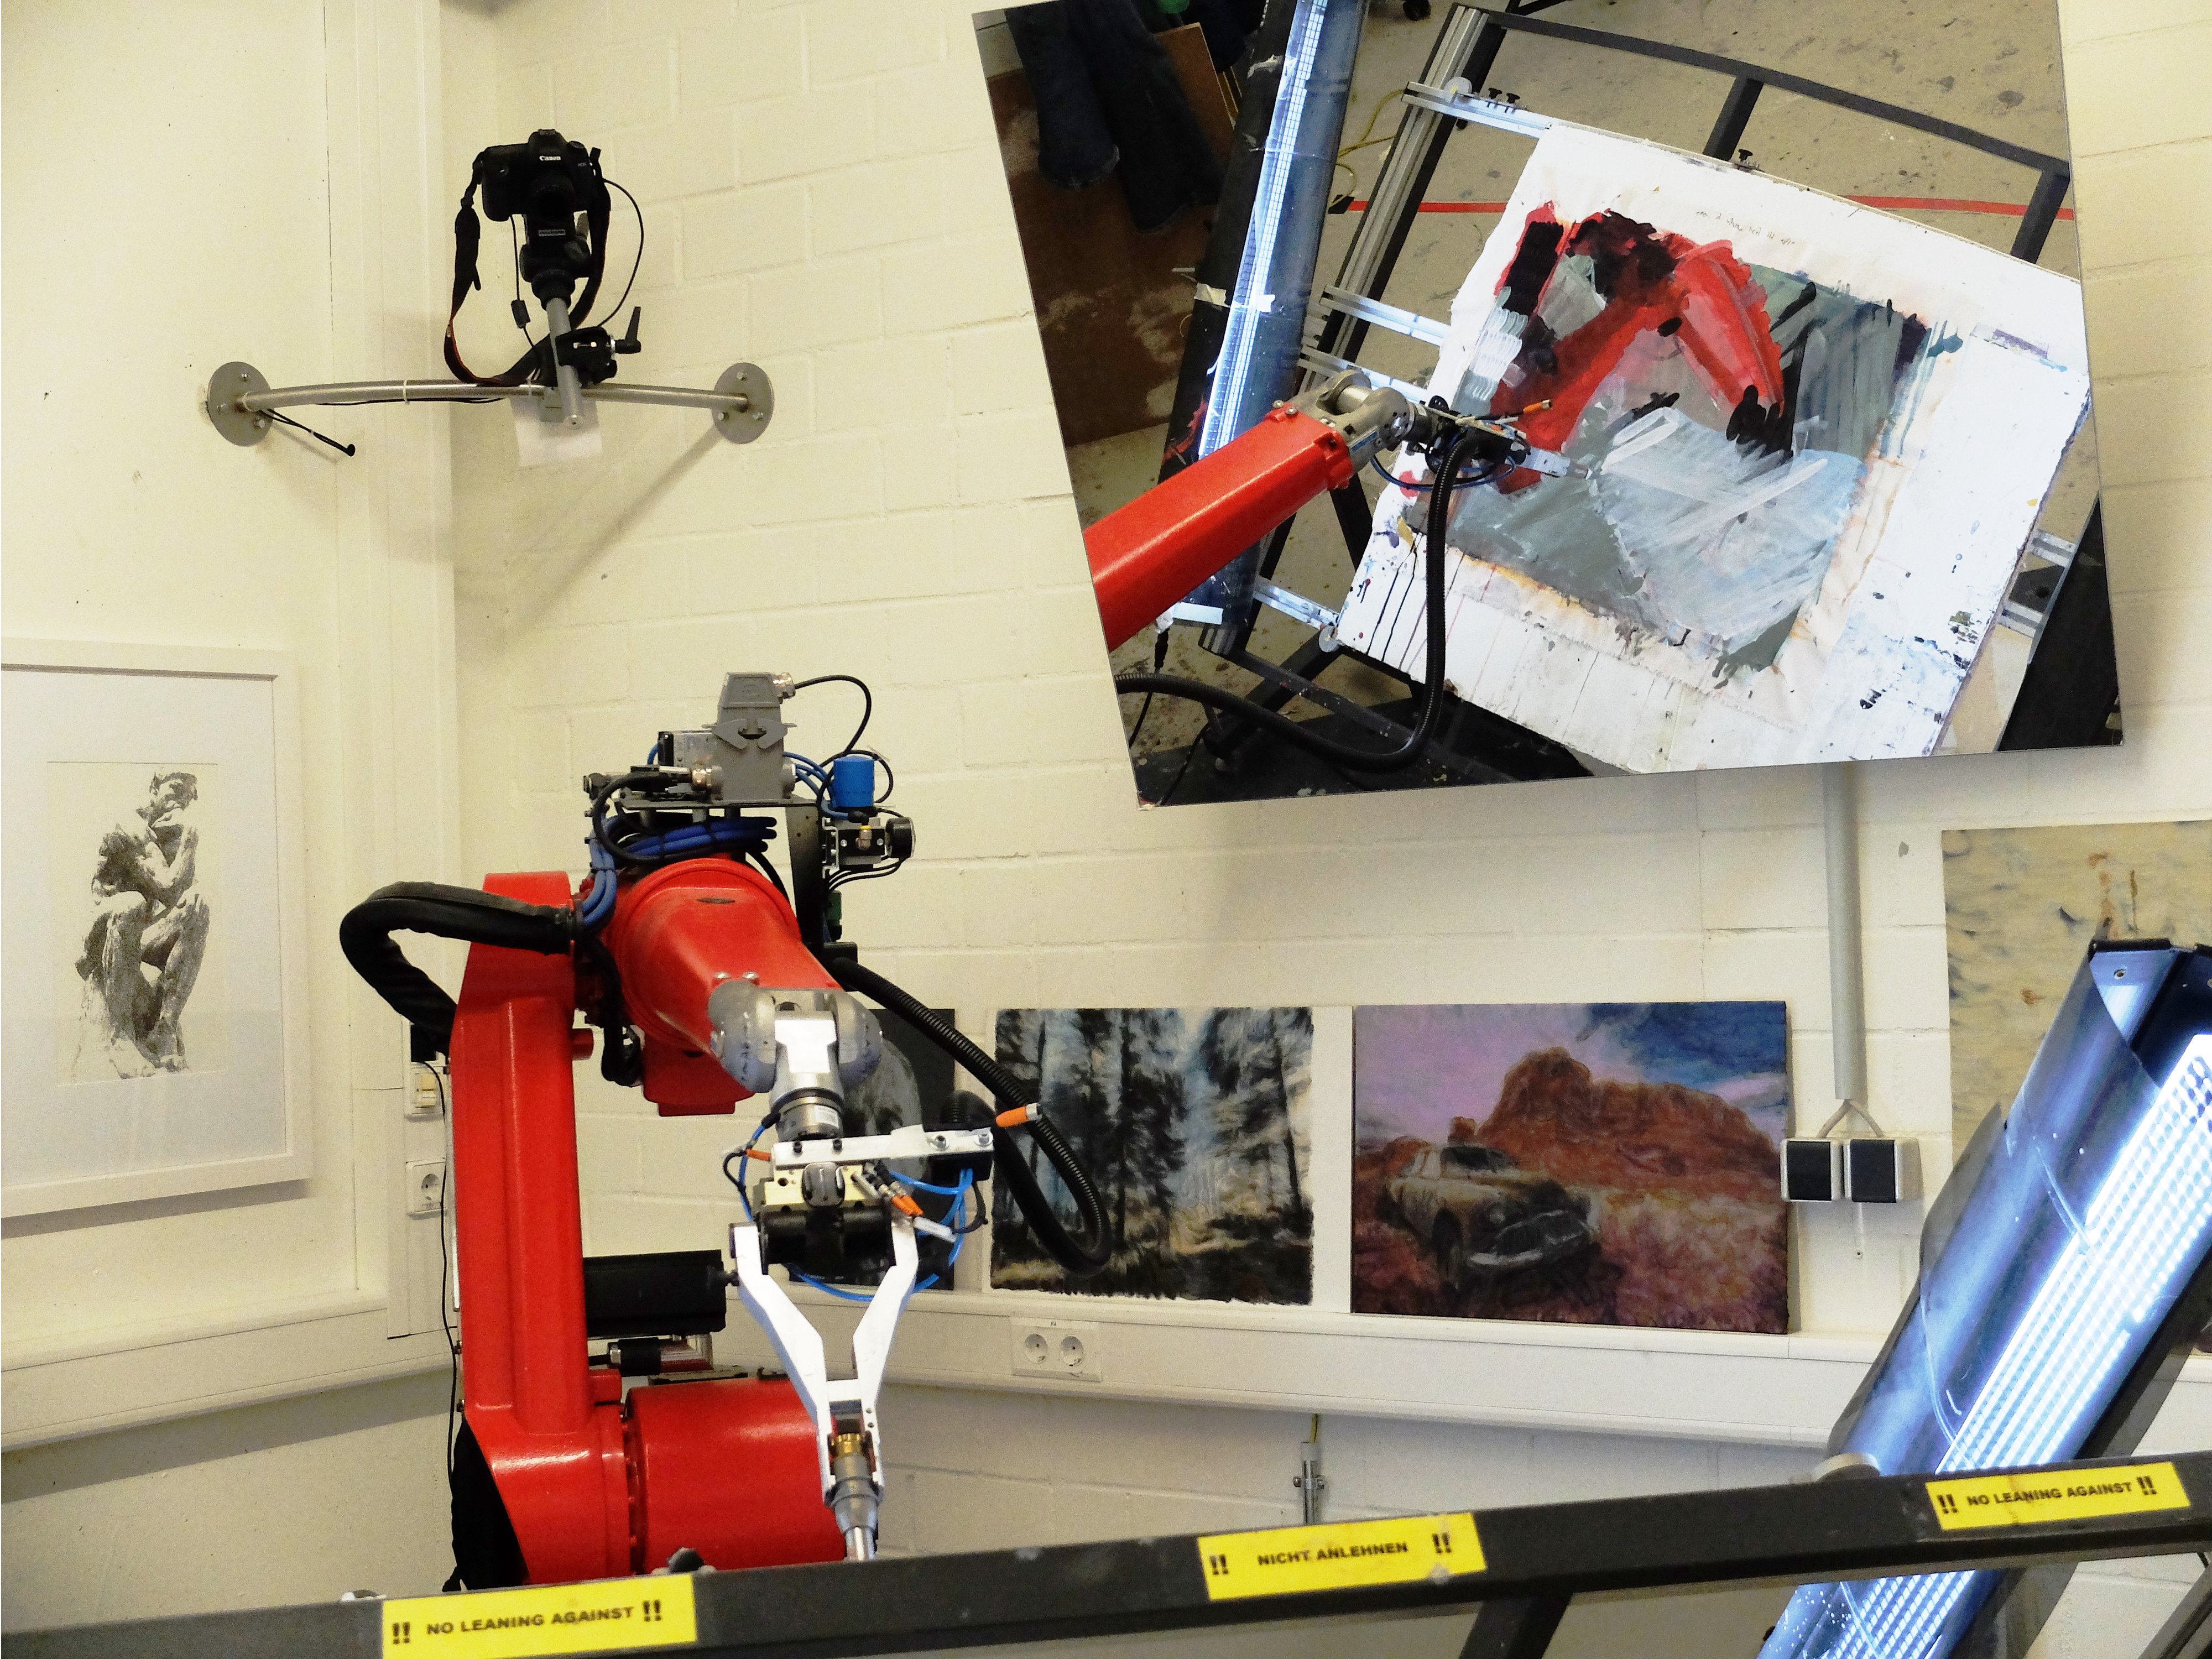
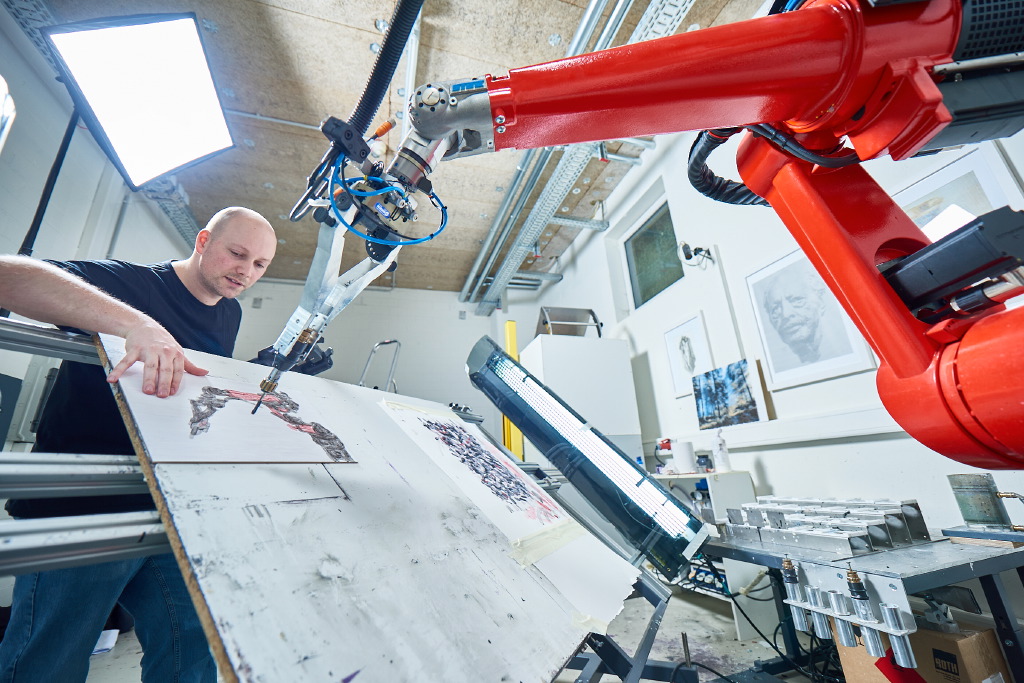
e-David Painting His “Self Portrait”
In this photo, we see e-David painting and the digital camera that is part of the visual feedback system used to continuously control and adjust the robot’s painting process. The mirror allows us to oversee the process from outside the reach of the robotic arm.
Videos & links
Video for the exhibition 'Brushstrokes in the Digital Age' where e-David smaller version and some of the paintings created in collaboration with Liat Grayver were shown.
Painting sequence of the self portrait.
- e-David Self-Portrait - Liat Grayver and Thomas Lindemeier - November 2016
The linked pdf contains a more detailed description of the creation of the e-David selfportrait
Comments
Comments are closed.